Electric Claw Plugin Source Code Overview
About This Document
This document is the source code guide for the Electric Claw project. It focuses on the code structure and core logic implementation of the two source folders, electricclawplugin-hmi and electricclawplugin-controller, for secondary development reference.
For general plugin concepts and the dual-side architecture, see Rokae+ Plugin Introduction; they are not repeated here.
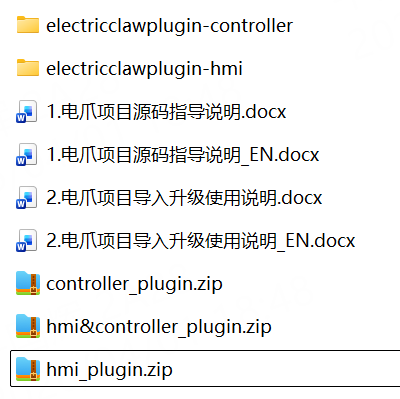
Source Code Download
| File | Description |
|---|---|
| 插件demo-电爪案例的源码及说明.zip | Full source code (HMI + controller) and documentation of the Electric Claw project |
Source Composition
| Folder | Content | Description |
|---|---|---|
| electricclawplugin-hmi | HMI (teach pendant) plugin source | Process package UI, electric claw status monitoring, RL assisted programming instructions. See Client Plugin Description |
| electricclawplugin-controller | Controller plugin source | RL instruction execution, electric claw control API, HMI instruction processing. See Controller Plugin Description |
Dual-Side Division of Work
The Electric Claw project is a typical example of client-controller cooperation:
- The HMI plugin is responsible for UI display and status monitoring. It registers RL editor instructions (
OnrobotMove,OnrobotStop,OnrobotStatus) that only generate instruction strings and do not execute RL logic; - The controller plugin performs the actual electric claw control and status acquisition, processes plugin instructions from the HMI, and executes RL instructions;
- The overlapping functionality of both sides (start, stop, get status) is extracted into the controller plugin API module for unified implementation.
Reading Guide
- Client Plugin Description: project structure and core code logic
- Controller Plugin Description: directory structure and code module description